Koopman-inspired Implicit Backward Reachable Sets for Unknown Nonlinear Systems
Abstract
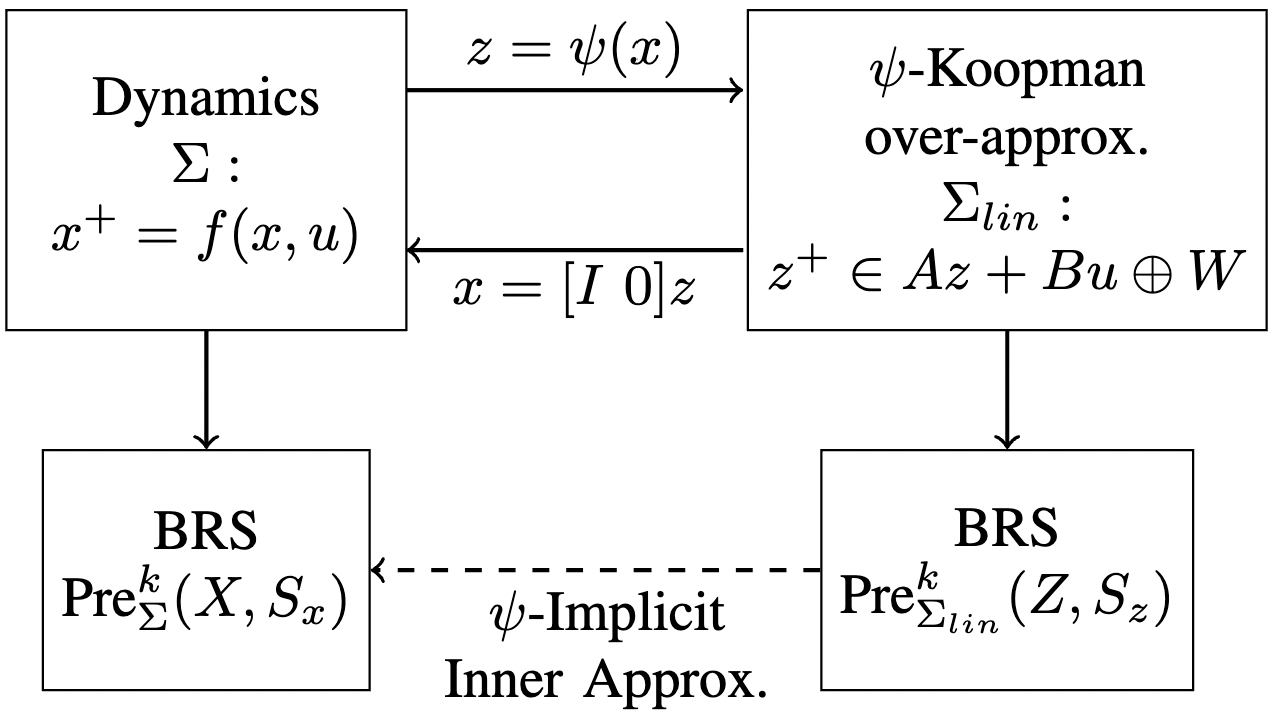
Koopman liftings have been successfully used to learn high dimensional linear approximations for autonomous systems for prediction purposes, or for control systems for leveraging linear control techniques to control nonlinear dynamics. In this letter, we show how learned Koopman approximations can be used for state-feedback correct-by-construction control. To this end, we introduce the Koopman over-approximation, a (possibly hybrid) lifted representation that has a simulation-like relation with the underlying dynamics. Then, we prove how successive application of controlled predecessor operation in the lifted space leads to an implicit backward reachable set for the actual dynamics. Finally, we demonstrate the approach on two nonlinear control examples with unknown dynamics.
Results
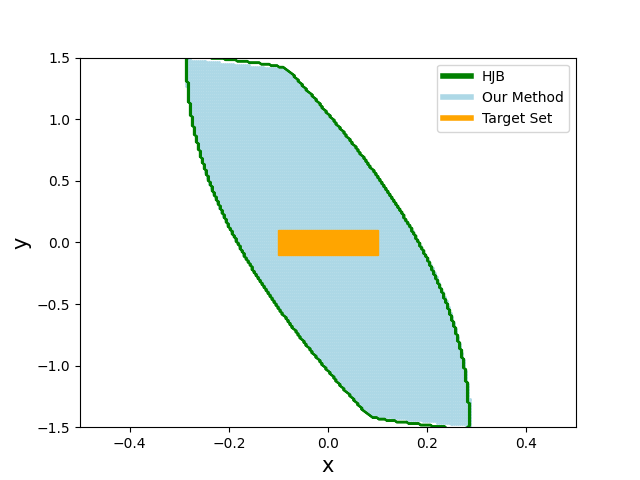
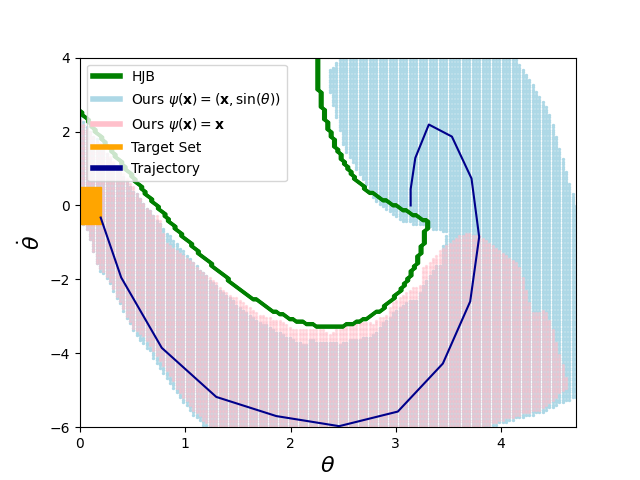
We present computed backward reachable sets by our method on the forced duffing oscillator (left) and pendulum (right).
BibTeX
@ARTICLE{10153400,
  author={Balim, Haldun and Aspeel, Antoine and Liu, Zexiang and Ozay, Necmiye},
  journal={IEEE Control Systems Letters},
  title={Koopman-Inspired Implicit Backward Reachable Sets for Unknown Nonlinear Systems},
  year={2023},
  volume={7},
  number={},
  pages={2245-2250},
  doi={10.1109/LCSYS.2023.3286126}
}