Haldun Balim

I am a Ph.D. candidate at Harvard SEAS, advised by Prof. Na Li and Prof. Yilun Du. Previously, I earned an M.Sc. in Robotics, Systems, and Control from ETH Zürich, where I worked at IDSC, and I was a visiting scholar at the University of Michigan, Ann Arbor. I also hold a double B.Sc. in Computer Science and Mechanical Engineering from Koç University.

I aim to design embodied agents that turn diverse experience into general competence in a complex and uncertain physical world. I pursue this through architectures that connect imagination and planning: learning models of the world, reasoning over possible futures, and translating that reasoning into decisions. My ambition is for a robot’s experience to be the foundation for expanding its capabilities rather than the boundary that defines them: robots that reason through unfamiliar tasks, identify what they need to learn, and compose new skills through planning.
Photo of Haldun Balim

Recent News

Oct 2026 Generative Trajectory Planning (GTP) will appear at NeurIPS 2026! Paper, code and models are out.
Jul 2026 New preprint with Haitong Ma, Yang Hu, Bo Dai and Na Li: a single diffusion-policy controller for multi-task block pushing, with zero-shot sim-to-real transfer.
Jul 2026 MPDiffuser appeared at ICML 2026 in Seoul and was featured in Nebius.Science’s ICML 2026: Papers That Matter.
Jun 2026 Diffusion-MPC for flexible legged locomotion was presented at ICRA 2026. Read the Harvard SEAS story.
May 2026 New preprint with Yuyang Zhang and Na Li: decentralized diffusion policy learning for exploration in cooperative multi-agent RL.
Dec 2025 New preprint: MPDiffuser, compositional diffusion sampling for predictive control in offline decision making.
Oct 2025 New preprint with Runhan Huang, Heng Yang and Yilun Du: Diffusion-MPC for flexible legged locomotion.
Dec 2024 Stochastic Data-Driven Predictive Control accepted to IEEE Control Systems Letters.
Sep 2024 Started my Ph.D. at Harvard SEAS, advised by Na Li and Yilun Du.
Jun 2024 Finished my M.Sc. in Robotics, Systems and Control at ETH Zürich!
Jun 2023 Koopman-inspired Implicit Backward Reachable Sets published in IEEE Control Systems Letters.
Jun 2023 EFE: End-to-End Frame-to-Gaze Estimation appeared at the CVPR 2023 GAZE workshop.
Sep 2021 Started my M.Sc. in Robotics, Systems and Control at ETH Zürich.
Jun 2021 Graduated from Koç University with a double B.Sc. in Computer Science and Mechanical Engineering.

Publications

* equal contribution  ·  † equal advising
Model-Based Online Decision Making via Generative Trajectory Planning
Haldun Balim, Yilun Du†, Na Li†
NeurIPS, 2026
/ paper / project page / code / models
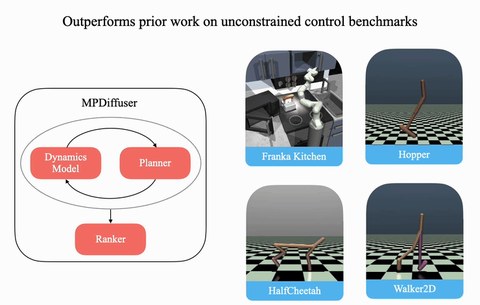
Model-Based Diffusion Sampling for Predictive Control in Offline Decision Making
Haldun Balim, Na Li, Yilun Du
ICML, 2026
Featured in Nebius.Science ICML 2026: Papers That Matter
/ paper / arXiv / project page / code
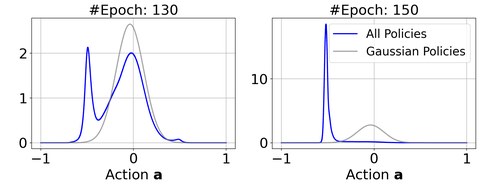
Decentralized Diffusion Policy Learning for Enhanced Exploration in Cooperative Multi-agent Reinforcement Learning
Yuyang Zhang, Haldun Balim, Na Li
arXiv preprint, 2026
/ arXiv
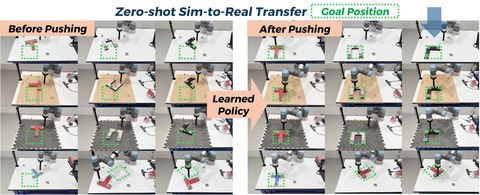
A Single Diffusion-Policy Controller for Multi-Task Block Pushing with Zero-Shot Sim-to-Real Transfer
Haitong Ma, Haldun Balim, Yang Hu, Bo Dai, Na Li
arXiv preprint, 2026
/ arXiv
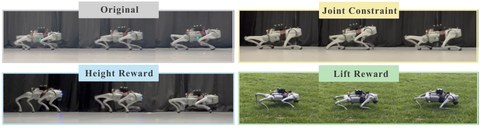
Flexible Locomotion Learning with Diffusion Model Predictive Control
Runhan Huang, Haldun Balim, Heng Yang, Yilun Du
ICRA, 2026
/ arXiv / press
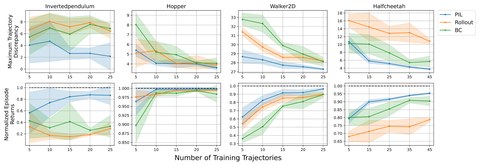
A Model-Based Approach to Imitation Learning through Multi-Step Predictions
Haldun Balim, Yang Hu, Yuyang Zhang, Na Li
IEEE CDC, 2025
/ paper / arXiv
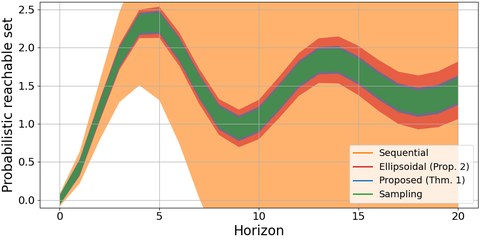
Stochastic Data-Driven Predictive Control: Chance-Constraint Satisfaction with Identified Multi-Step Predictors
Haldun Balim, Andrea Carron, Melanie N. Zeilinger, Johannes Köhler
IEEE Control Systems Letters (L-CSS), 2024
/ paper / arXiv / code
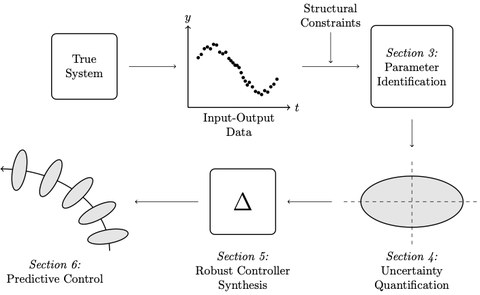
From Data to Predictive Control: A Framework for Stochastic Linear Systems with Output Measurements
Haldun Balim, Andrea Carron, Melanie N. Zeilinger, Johannes Köhler
arXiv preprint, 2024
/ arXiv / code
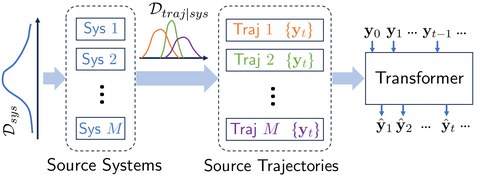
Can Transformers Learn Optimal Filtering for Unknown Systems?
Haldun Balim*, Zhe Du*, Samet Oymak, Necmiye Ozay
IEEE Control Systems Letters (L-CSS), 2023
/ paper / arXiv / code
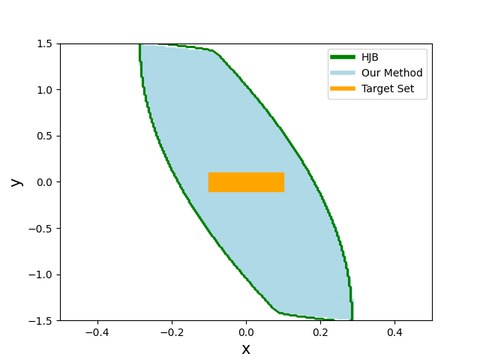
Koopman-inspired Implicit Backward Reachable Sets for Unknown Nonlinear Systems
Haldun Balim, Antoine Aspeel, Zexiang Liu, Necmiye Ozay
IEEE Control Systems Letters (L-CSS), 2023
/ paper / arXiv / project page / code
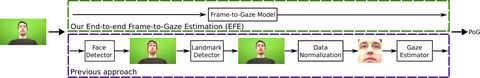
EFE: End-to-End Frame-to-Gaze Estimation
Haldun Balim, Seonwook Park, Xi Wang, Xucong Zhang, Otmar Hilliges
CVPR Workshops (GAZE), 2023
/ paper / arXiv
Automated Diagnosis of Keratoconus from Corneal Topography
Ayse Yildiz Tas, Murat Hasanreisoglu, Haldun Balim, Mehmet Gönen, Afsun Sahin
Investigative Ophthalmology & Visual Science (ARVO abstract), 2021
Recurrent Neural Network-Based Intention Estimation Frameworks for Power-Assisted Manual Wheelchair Users: A Feasibility Study
Haldun Balim, Mahsa Khalili, Calvin Kuo, H.F. Machiel Van der Loos, Jamie F. Borisoff
RO-MAN Workshops, 2020
pdf
In Vitro Validation of a Self-Driving Aortic-Turbine Venous-Assist Device for Fontan Patients
Kerem Pekkan, Ibrahim Basar Aka, Ece Tutsak, Erhan Ermek, Haldun Balim, Ismail Lazoglu, Riza Turkoz
The Journal of Thoracic and Cardiovascular Surgery, 2018
paper

More on Google Scholar →